
[isaacsim.asset.importer.mjcf] MJCF Importer#
Version: 3.13.0
Overview#
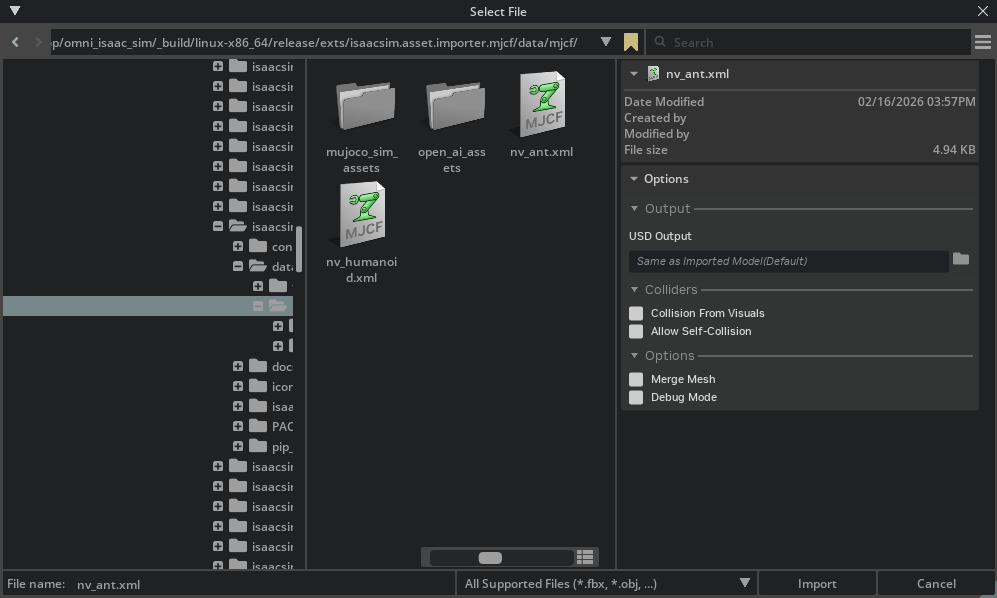
To enable this extension, go to the Extension Manager menu and enable isaacsim.asset.importer.mjcf extension.
High Level Code Overview#
Python#
The MJCF Importer extension uses MJCFImporterConfig, a dataclass that stores configuration
settings for MJCF import operations. The UI extension allows users to modify these settings
through a graphical interface. Configuration fields can be set directly on the dataclass instance.
The main entry point is the MJCFImporter class, which takes
an optional MJCFImporterConfig instance. The importer uses the mujoco-usd-converter library
to convert MJCF files to USD format.
Example usage:
.. code-block:: python
from isaacsim.asset.importer.mjcf import MJCFImporter, MJCFImporterConfig

# Create configuration
config = MJCFImporterConfig(
    mjcf_path="/path/to/robot.xml",
    usd_path="/path/to/output",
    merge_mesh=True,
    collision_from_visuals=True
)

# Create importer and import
importer = MJCFImporter(config)
output_path = importer.import_mjcf()
Note: The commands MJCFCreateAsset and MJCFCreateImportConfig in python/impl/command.py
are deprecated and should not be used in new code. Use MJCFImporter and MJCFImporterConfig directly instead.
Enable Extension#
The extension can be enabled (if not already) in one of the following ways:
Define the next entry as an application argument from a terminal.
APP_SCRIPT.(sh|bat) --enable isaacsim.asset.importer.mjcf
Define the next entry under [dependencies] in an experience (.kit) file or an extension configuration (extension.toml) file.
[dependencies]
"isaacsim.asset.importer.mjcf" = {}
Open the Window > Extensions menu in a running application instance and search for isaacsim.asset.importer.mjcf.
Then, toggle the enable control button if it is not already active.
Commands#
Public command API for module isaacsim.asset.importer.mjcf:
MJCFCreateAsset (deprecated)#
.. deprecated::
Use MJCFImporter() directly instead.
This command parses and imports a given mjcf file. It is deprecated and will be removed in a future version.
Arguments#
mjcf_path
import_config
prim_path
dest_path
MJCFCreateImportConfig (deprecated)#
.. deprecated::
Use MJCFImporterConfig() directly instead.
Returns an ImportConfig object that can be used while parsing and importing. It is deprecated and will be removed in a future version.
MJCF Importer Extension [isaacsim.asset.importer.mjcf]#
MJCF Import Workflow#
Use the MJCF importer configuration and converter classes to import MJCF files into USD. Below is a sample demonstrating how to import the Ant MJCF included with this extension.
 1import omni.usd
 2from isaacsim.asset.importer.mjcf import MJCFImporter, MJCFImporterConfig
 3from isaacsim.asset.importer.utils import stage_utils
 4
 5# Get path to extension data:
 6ext_manager = omni.kit.app.get_app().get_extension_manager()
 7ext_id = ext_manager.get_enabled_extension_id("isaacsim.asset.importer.mjcf")
 8extension_path = ext_manager.get_extension_path(ext_id)
 9
10# setting up import configuration:
11config = MJCFImporterConfig(mjcf_path=extension_path + "/data/mjcf/nv_ant.xml")
12
13# import MJCF
14importer = MJCFImporter(config)
15output_path = importer.import_mjcf()
16
17# open the resulting USD for inspection
18stage = stage_utils.open_stage(output_path)
- class MJCFImporter(
- config: MJCFImporterConfig | None = None,
MuJoCo MJCF to USD importer.
Uses mujoco-usd-converter to convert MJCF files to USD format.
- Parameters:
config – Optional configuration for the import operation.
Example:
>>> from isaacsim.asset.importer.mjcf import MJCFImporter
>>> MJCFImporter()
<...>
- import_mjcf(
- config: MJCFImporterConfig | None = None,
Import an MJCF file and convert it to USD.
- Parameters:
config – Optional configuration for the import operation. If not provided, the stored importer configuration will be used.
- Returns:
Path to the generated USD file.
- Raises:
ValueError – If the MJCF path is not configured or if the file does not have a
.xmlextension.FileNotFoundError – If the MJCF file does not exist at the given path.
Example:
>>> from isaacsim.asset.importer.mjcf import MJCFImporter, MJCFImporterConfig

>>> importer = MJCFImporter()
>>> config = MJCFImporterConfig(mjcf_path="/tmp/robot.xml")
>>> importer.config = config
>>> # output_path = importer.import_mjcf()
- property config: MJCFImporterConfig#
Get the importer configuration.
- Returns:
Current importer configuration.
Example:
>>> from isaacsim.asset.importer.mjcf import MJCFImporter, MJCFImporterConfig

>>> importer = MJCFImporter()
>>> importer.config
MJCFImporterConfig(...)
- class MJCFImporterConfig(
- mjcf_path: str | None = None,
- usd_path: str | None = None,
- import_scene: bool = True,
- merge_mesh: bool = False,
- debug_mode: bool = False,
- collision_from_visuals: bool = False,
- collision_type: str = 'Convex Hull',
- allow_self_collision: bool = False,
- robot_type: str = 'Default',
- fix_base: bool | None = None,
- link_density: float | None = None,
- joint_drive_type: str | dict[str, str] | None = None,
- joint_target_type: str | dict[str, str] | None = None,
- override_gain_type: str | None = None,
- override_bias_type: str | None = None,
- override_gain_prm: list[float] | None = None,
- override_bias_prm: list[float] | None = None,
- run_asset_transformer: bool = True,
- run_multi_physics_conversion: bool = True,
Configuration for MJCF import operations.
Stores settings that control how MJCF files are converted to USD.
- Parameters:
mjcf_path – Path to the MJCF (.xml) file to import.
usd_path – Directory path where the USD file will be saved. When left at its default of
None,MJCFImporter.import_mjcf()will mutate this field in-place toos.path.dirname(mjcf_path)(the directory containing the source MJCF) and write all USD output there. Pass an explicit value to keep import outputs out of the source tree.import_scene – If True, imports the MJCF simulation settings along with the model.
merge_mesh – If True, merges meshes where possible to optimize the model.
debug_mode – If True, enables debug mode with additional logging and visualization.
collision_from_visuals – If True, collision geometry is generated from visual geometries.
collision_type – Type of collision geometry to use. Options: “Convex Hull”, “Convex Decomposition”, “Bounding Sphere”, “Bounding Cube”.
allow_self_collision – If True, allows the model to collide with itself.
fix_base –
Tri-state base-type toggle.
True: adds a fixed joint from the world to the root rigid-body link and relocates ArticulationRootAPI to the correct ancestor prim.False: removes any existing world-to-root fixed joint so the robot becomes floating-base.None(default): leaves the source asset’s base authoring untouched.
link_density – Default density (kg/m^3) applied to rigid body links that have no explicit mass.
Nonemeans no density override.override_gain_type – MuJoCo actuator gain type (e.g.
"fixed").Noneleaves existing value.override_bias_type – MuJoCo actuator bias type (e.g.
"affine").Noneleaves existing value.override_gain_prm – MuJoCo actuator gain parameter array (10 floats).
Noneleaves existing value. Position control example:[kp, 0, 0, 0, 0, 0, 0, 0, 0, 0].override_bias_prm – MuJoCo actuator bias parameter array (10 floats).
Noneleaves existing value. Position control example:[0, -kp, -kd, 0, 0, 0, 0, 0, 0, 0].run_asset_transformer – If True, runs the asset transformer profile after conversion to restructure the USD output.
run_multi_physics_conversion – If True, runs MuJoCo-to-PhysX physics conversion on the imported stage.
Example:
>>> from isaacsim.asset.importer.mjcf import MJCFImporterConfig

>>> config = MJCFImporterConfig(
...     mjcf_path="/tmp/robot.xml",
...     usd_path="/tmp/output",
...     merge_mesh=True
... )
>>> config.mjcf_path
'/tmp/robot.xml'
- allow_self_collision: bool = False#
- collision_from_visuals: bool = False#
- collision_type: str = 'Convex Hull'#
- debug_mode: bool = False#
- import_scene: bool = True#
- merge_mesh: bool = False#
- robot_type: str = 'Default'#
- run_asset_transformer: bool = True#
- run_multi_physics_conversion: bool = True#